Mechanics & electronics
Mechanical structures, joint drives, power systems and communication buses.
We develop quadruped robots and intelligent systems for inspection, emergency operations, research and education. Alongside the hardware, we provide development interfaces, simulation tools and deployment support.
Development covers mechanics, electronics, motion control, perception and software, supporting both product development and on-site testing.
Mechanical structures, joint drives, power systems and communication buses.
Gait control, posture stability, state estimation and terrain adaptation.
Vision, sensor fusion, obstacle recognition and environment understanding.
ROS, SDKs, APIs, simulation platforms and data interfaces.
Select a robot by terrain, payload and task requirements, then test it in research, inspection or site operations.
Record operating states, sensor data and task results to investigate issues and adjust algorithms and models.
Document task configurations, test records and operating experience for future deployments.
Design inspection solutions for factories, campuses, warehouses and mining sites around task templates, remote operations and data records, with fleet coordination as a development direction.
Explore application solutions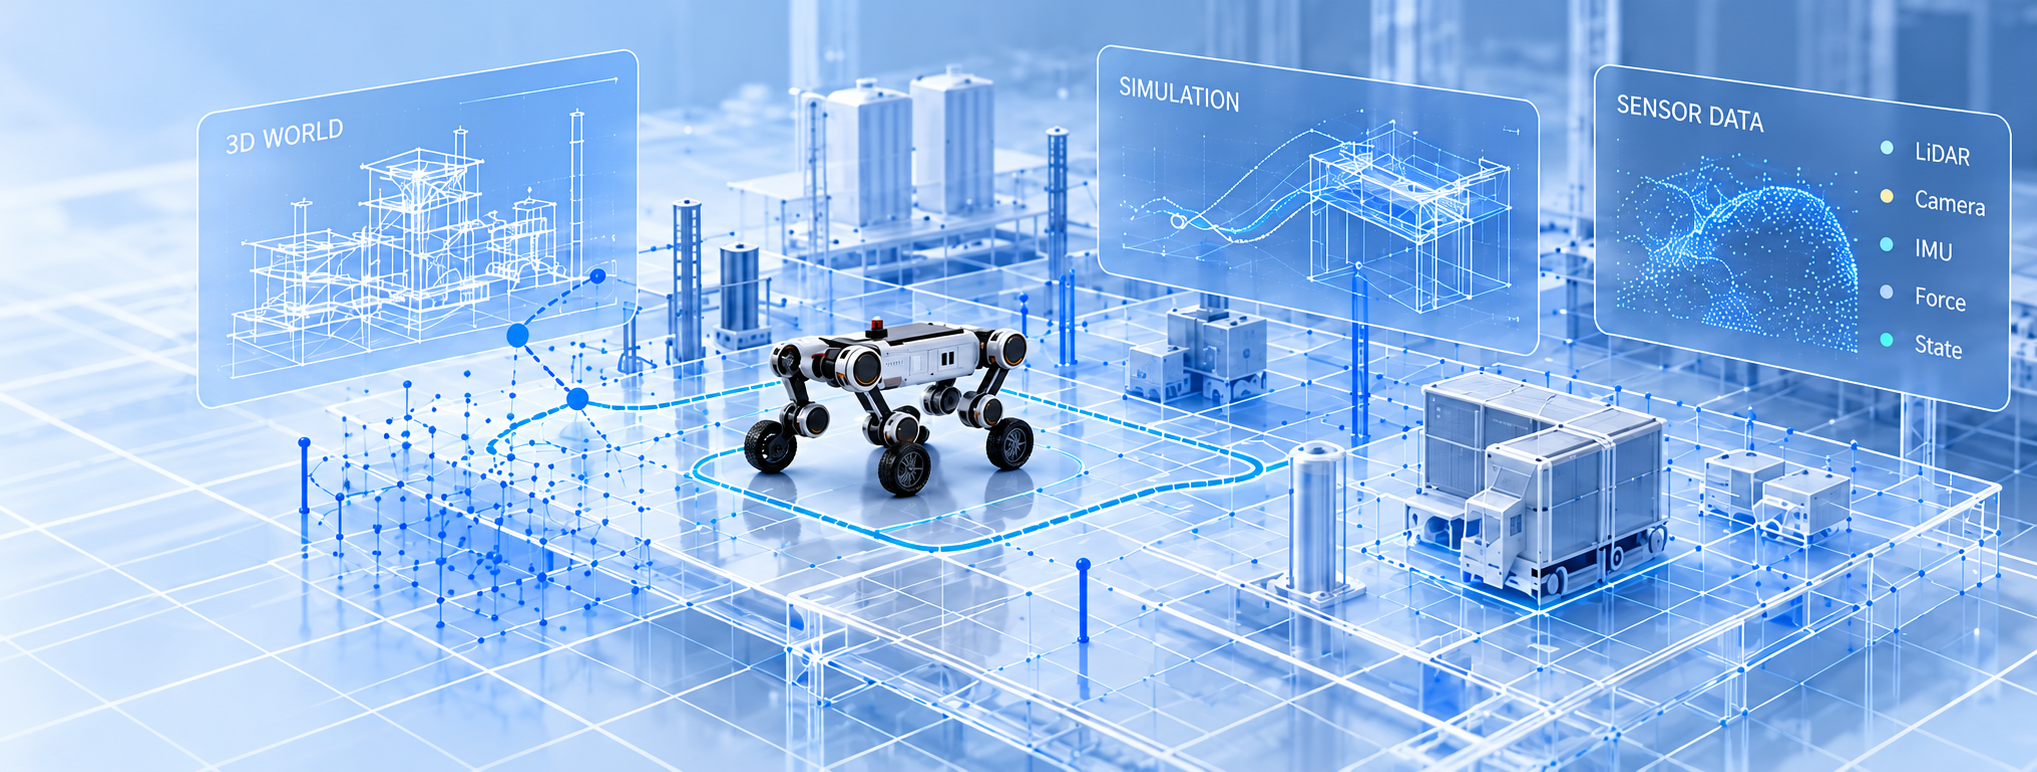
Describe your site, equipment and operating requirements in a downloadable project brief.
Prepare a brief