Robot hardware
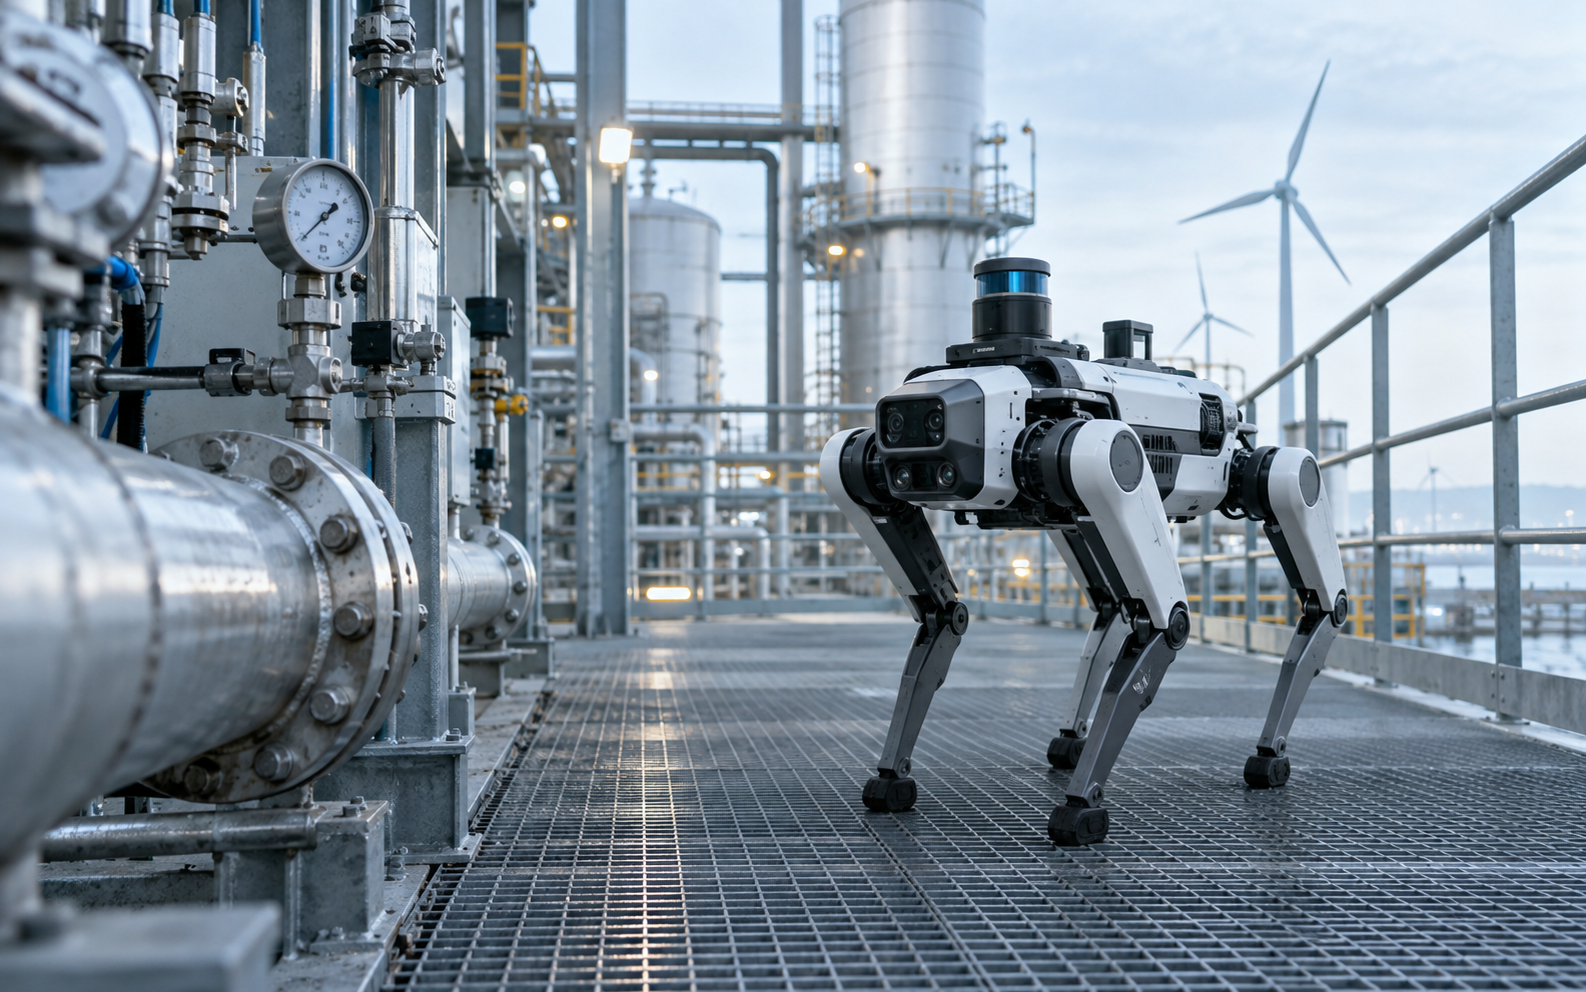
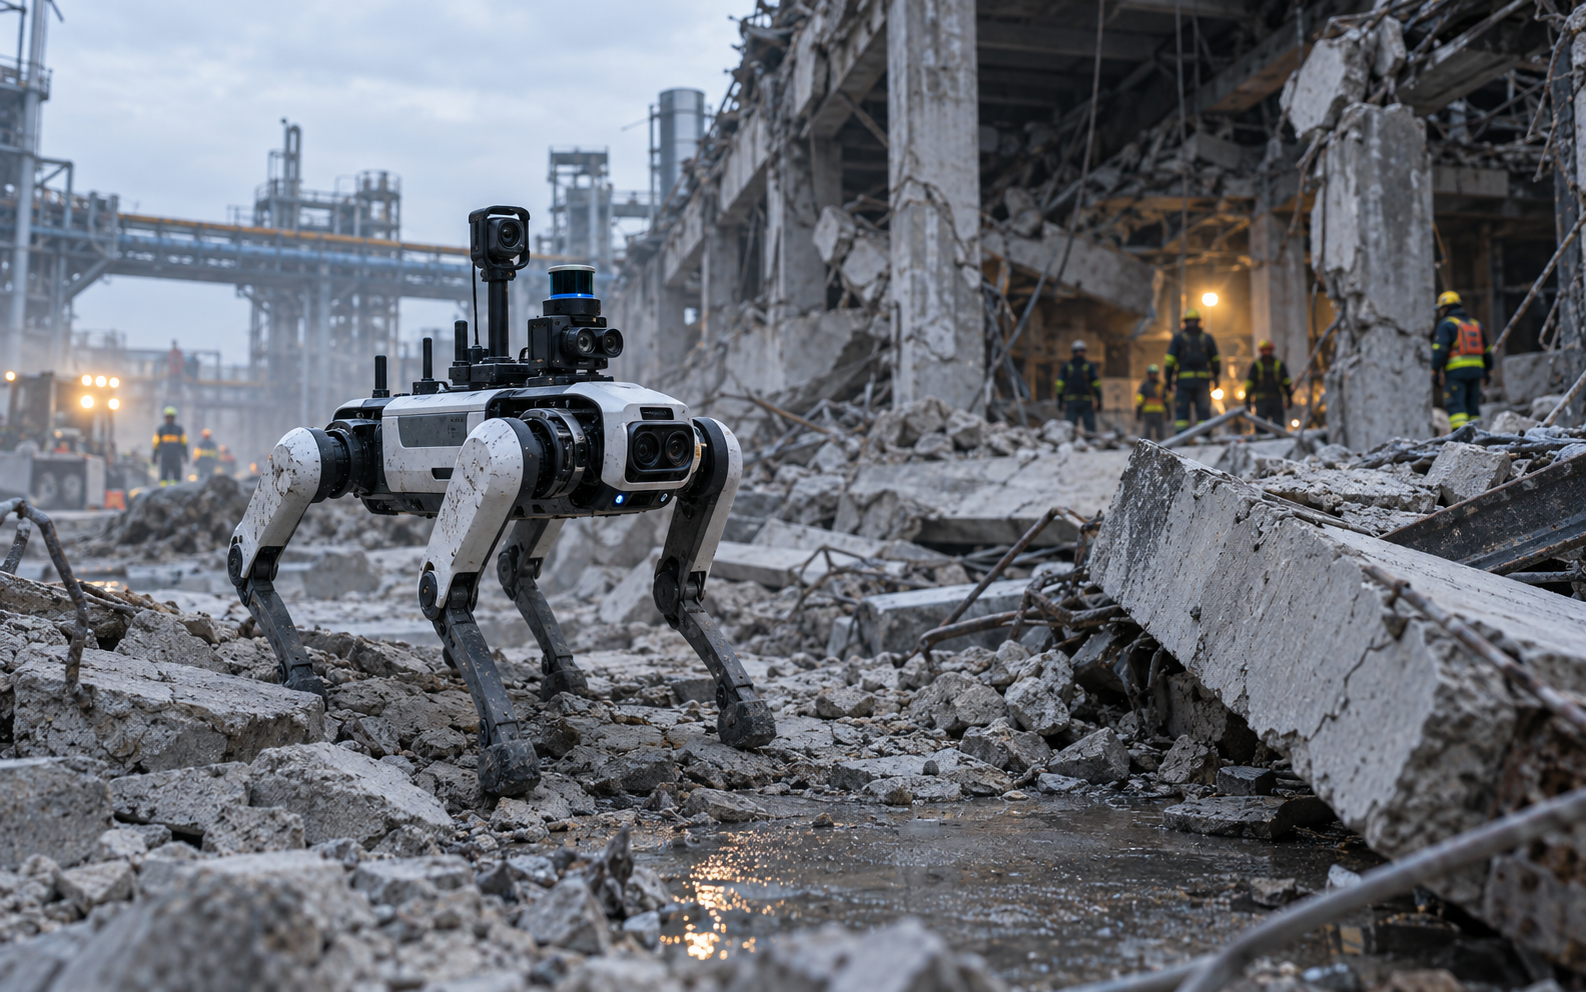
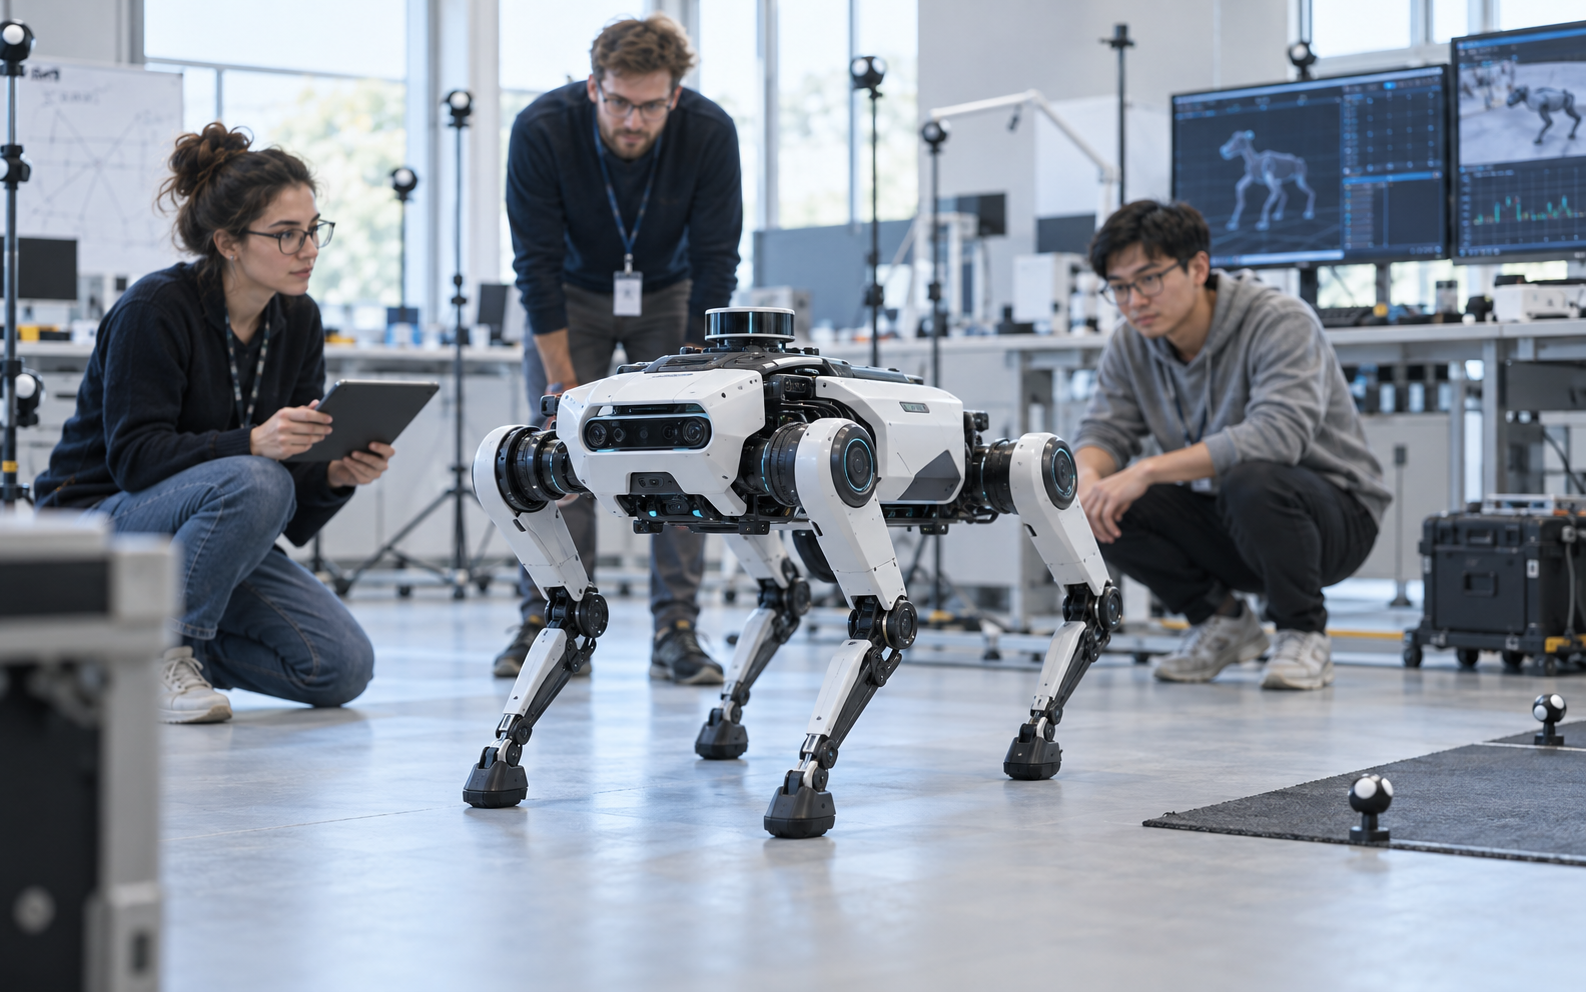
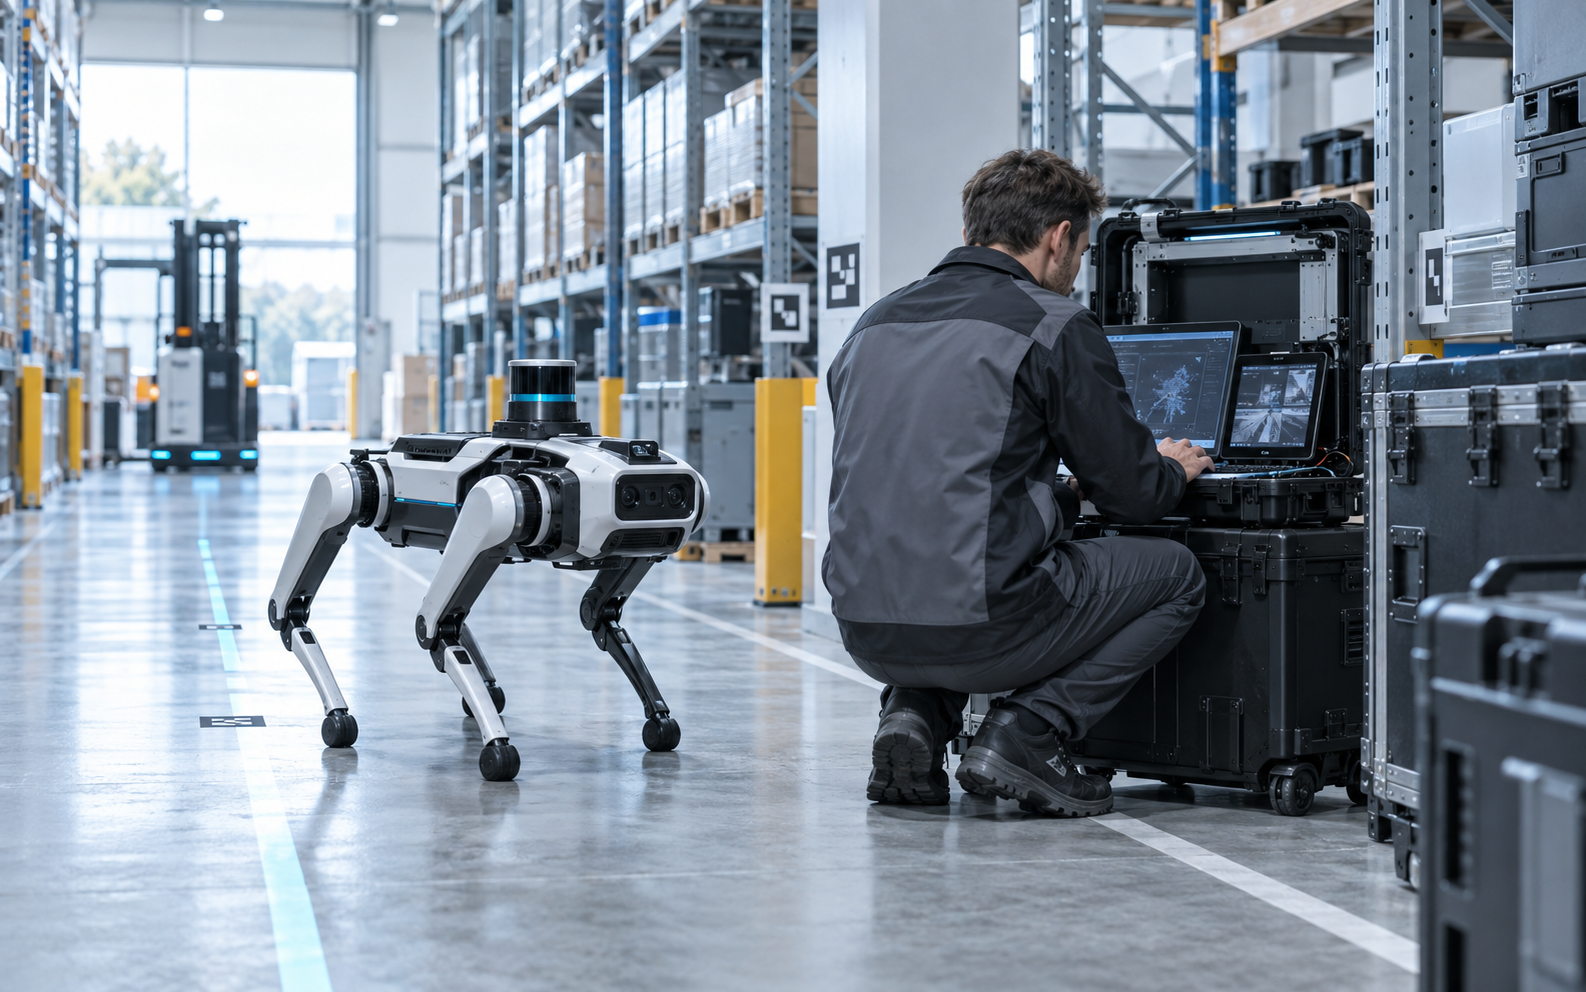
A reliable platform for real-world execution
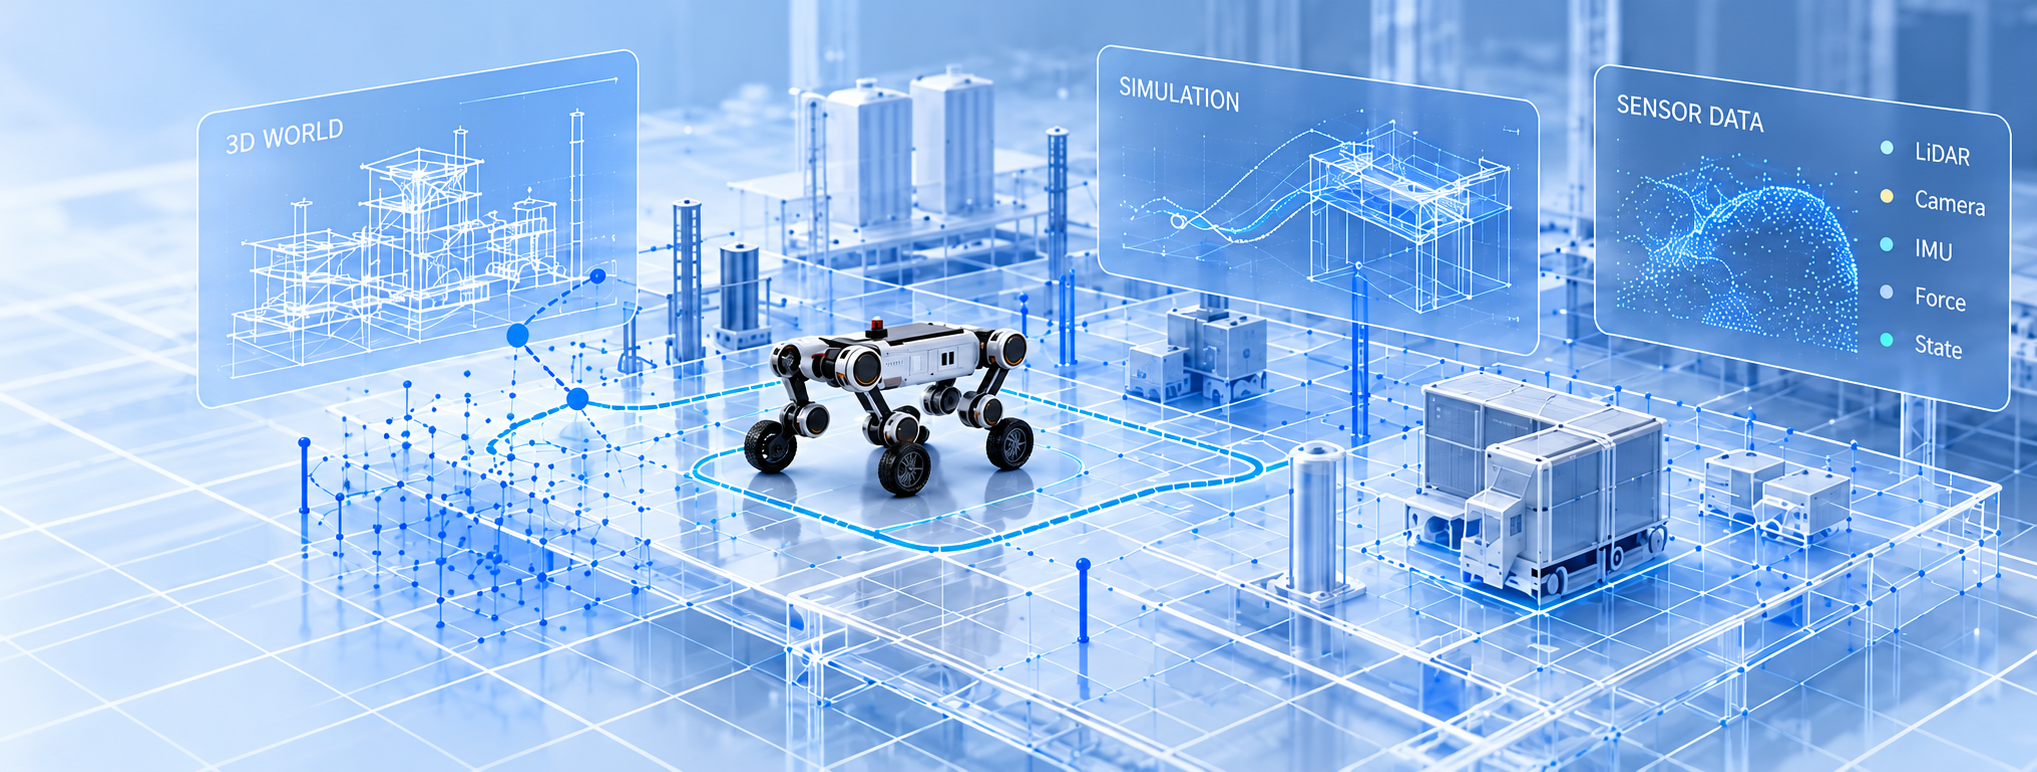
Test robot policies with scene reconstruction and physics simulation, then review and refine them using field data.
A reliable platform for real-world execution
Build repeatable validation environments
Iterate strategies in virtual tasks
Feed task data back to improve capability
The architecture connects robot hardware, training environments, control systems and applications.
Solutions for real-world industries
Multimodal perception and task control
Verifiable, iterative training and evaluation
Real-world task data keeps improving models, hardware and industry applications.
Validate robotic capabilities against site conditions and task goals.
Collect LiDAR, camera and IMU data for reconstruction.
Reconstruct scene geometry and surface textures from captured data.
Vary layouts, materials, lighting and weather to create training scenarios.
Use MuJoCo / PhysX for contact, dynamics and sensor simulation.
Iteratively validate reinforcement learning, task planning and inspection policies.